Skip to content

Grade 10 · Core Mathematics · Lesson 20 of 21

Determining Translation Vectors as Transformations

A Grade 10 Core Mathematics CBE lesson from the sub-strand Vectors I. In it, learners determine the translation vector mapping an object point to an image point.

Strand Measurements and GeometrySub-strand Vectors ILesson code 10CM-28-L2040 minutes · 3 slides

KICD learning outcome (k)

Determine translation vector as a transformation.

By the end of this lesson, learners should be able to

  1. Determine the translation vector mapping an object point to an image point.
  2. Calculate original object coordinates given an image point and translation vector.
  3. Translate geometric shapes on the Cartesian plane using column vectors.

Key vocabulary

Translation vector
A column vector describing the magnitude and direction of horizontal and vertical shift.
The vector (47) maps point A(3,2) onto A′(7,9).
Image
The new position of a point or shape resulting from a geometric transformation.
Point B′(4,7) is the image of B(−1,10) under a translation.
Transformation
A mathematical operation that changes the position, size, or orientation of a shape.
Translation is a transformation mapping A(−2,1) to A′(3,8).

Lesson preview

Slide 1 · Determining Translation Vectors and Image PointsModel · 12 min
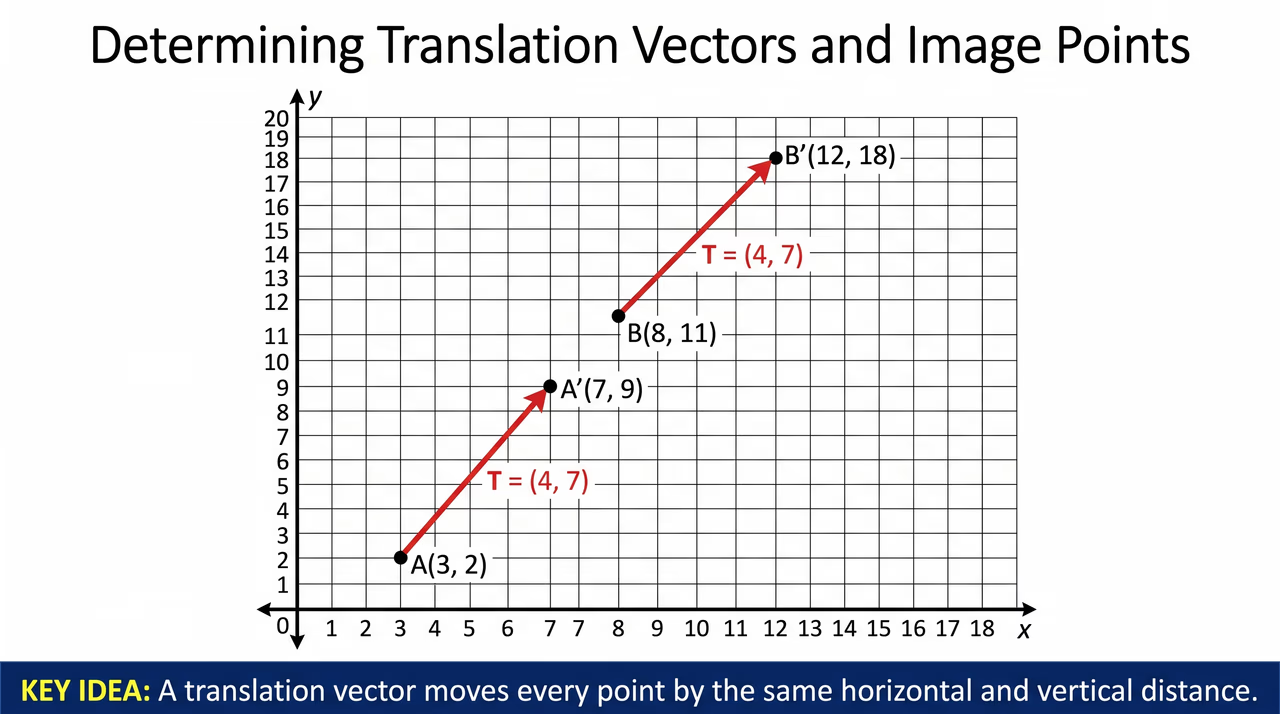
A coordinate plane shows the translation vector mapping point A to A' and point B to B'.
Figure 1: A coordinate plane shows the translation vector mapping point A to A' and point B to B'.

A translation is a transformation that shifts every point on a plane by the same distance in a specified direction. The translation vector T=(ab) gives the horizontal shift a and vertical shift b. When a point P(x,y) is mapped onto P′(x′,y′), the vector equation OP′⃗=OP⃗+T allows us to determine T=OP′⃗−OP⃗. We then use this same vector to translate any other point.

  • The translation vector T is calculated as the image position vector minus the object position vector T=OP′⃗−OP⃗.
  • Horizontal displacement a is the top component, and vertical displacement b is the bottom component of (ab).
  • Adding the translation vector T to any point's position vector gives the exact position vector of its image.
  • Every point of a translated shape moves along parallel paths of equal length determined by vector T.
Worked example. Write position vectors OA⃗=(32) and OA′⃗=(79). Calculate translation vector T=OA′⃗−OA⃗=(79)−(32)=(47). Apply vector T to B: OB′⃗=OB⃗+T=(811)+(47)=(1218). Answer: The translation vector is (47) and the image point is B′(12,18)..

Check question: A translation maps point M(−2,5) onto M′(1,8). What is the image of N(4,−1) under this same translation?

  1. N′(3,12)
  2. N′(1,−4)
  3. N′(3,2)
  4. N′(7,2)
Show answer

N′(7,2). First, find the translation vector T by subtracting the object position vector from the image position vector: T=(18)−(−25)=(1−(−2)8−5)=(33). To find the image of N, add T to ON⃗: ON′⃗=(4−1)+(33)=(72). Therefore, the image is N′(7,2).

Slide 2 · Finding Original Object Points and Translating ShapesPractice · 14 min
A coordinate grid displays an image point reversed to its object point by subtracting the translation vector.
Figure 2: A coordinate grid displays an image point reversed to its object point by subtracting the translation vector.

Teach the full lesson on the projector

This lesson, and every other Grade 1–10 CBE lesson, comes ready to project with the EAP ClassKit. It runs without electricity or internet.

  • All 3 slides with diagrams and class activities
  • Teacher notes, SNE adaptations and assessment checks
  • Homework and the other 20 lessons in this sub-strand

All 21 lessons in Vectors I

  1. 1Explaining Vector and Scalar QuantitiesExplain vector and scalar quantities with illustrations
  2. 2Using Vector Notations in Different WaysUse vector notations in different ways
  3. 3Representing Vectors GeometricallyRepresent vectors geometrically in different situations
  4. 4Representing Vectors Geometrically in Different SituationsRepresent vectors geometrically in different situations
  5. 5Identifying Equivalent VectorsIdentify equivalent vectors in different situations
  6. 6Equivalent VectorsIdentify equivalent vectors in different situations
  7. 7Adding Vectors GeometricallyAdd vectors in different situations
  8. 8Adding Vectors Geometrically in Different SituationsAdd vectors in different situations
  9. 9Multiplying Vectors by ScalarsMultiply vectors by scalars
  10. 10Multiplying Vectors by Scalars: Graphical Construction and Scalar RatiosMultiply vectors by scalars
  11. 11Determining Column Vectors from Coordinates and DiagramsDetermine column vectors in different situations
  12. 12Determining Column Vectors and Vector ArithmeticDetermine column vectors in different situations
  13. 13Determining Position Vectors from the OriginDetermine position vectors in different situations
  14. 14Determining Position Vectors and Calculating Vector DisplacementsDetermine position vectors in different situations
  15. 15Calculating the Magnitude of a VectorWork out magnitude of a vector in different situations
  16. 16Working Out Vector Magnitudes in Different SituationsWork out magnitude of a vector in different situations
  17. 17Determining the Midpoint of a VectorDetermine the midpoint of a vector in different situations
  18. 18Determining Vector Midpoints and Endpoint CoordinatesDetermine the midpoint of a vector in different situations
  19. 19Determining Translation Vector as a TransformationDetermine translation vector as a transformation
  20. 20Determining Translation Vectors as TransformationsDetermine translation vector as a transformation
  21. 21Appreciating Vectors in Real-Life SituationsAppreciate the use of vectors in real-life situations